AI & ML 2024 14 / 14
Marker Pose from Video
Computer vision that finds ArUco markers and measures distance and angle, frame by frame.
Built with
Language
- Python
Skills & tools
- OpenCV
- NumPy
- Computer vision
- Pose estimation
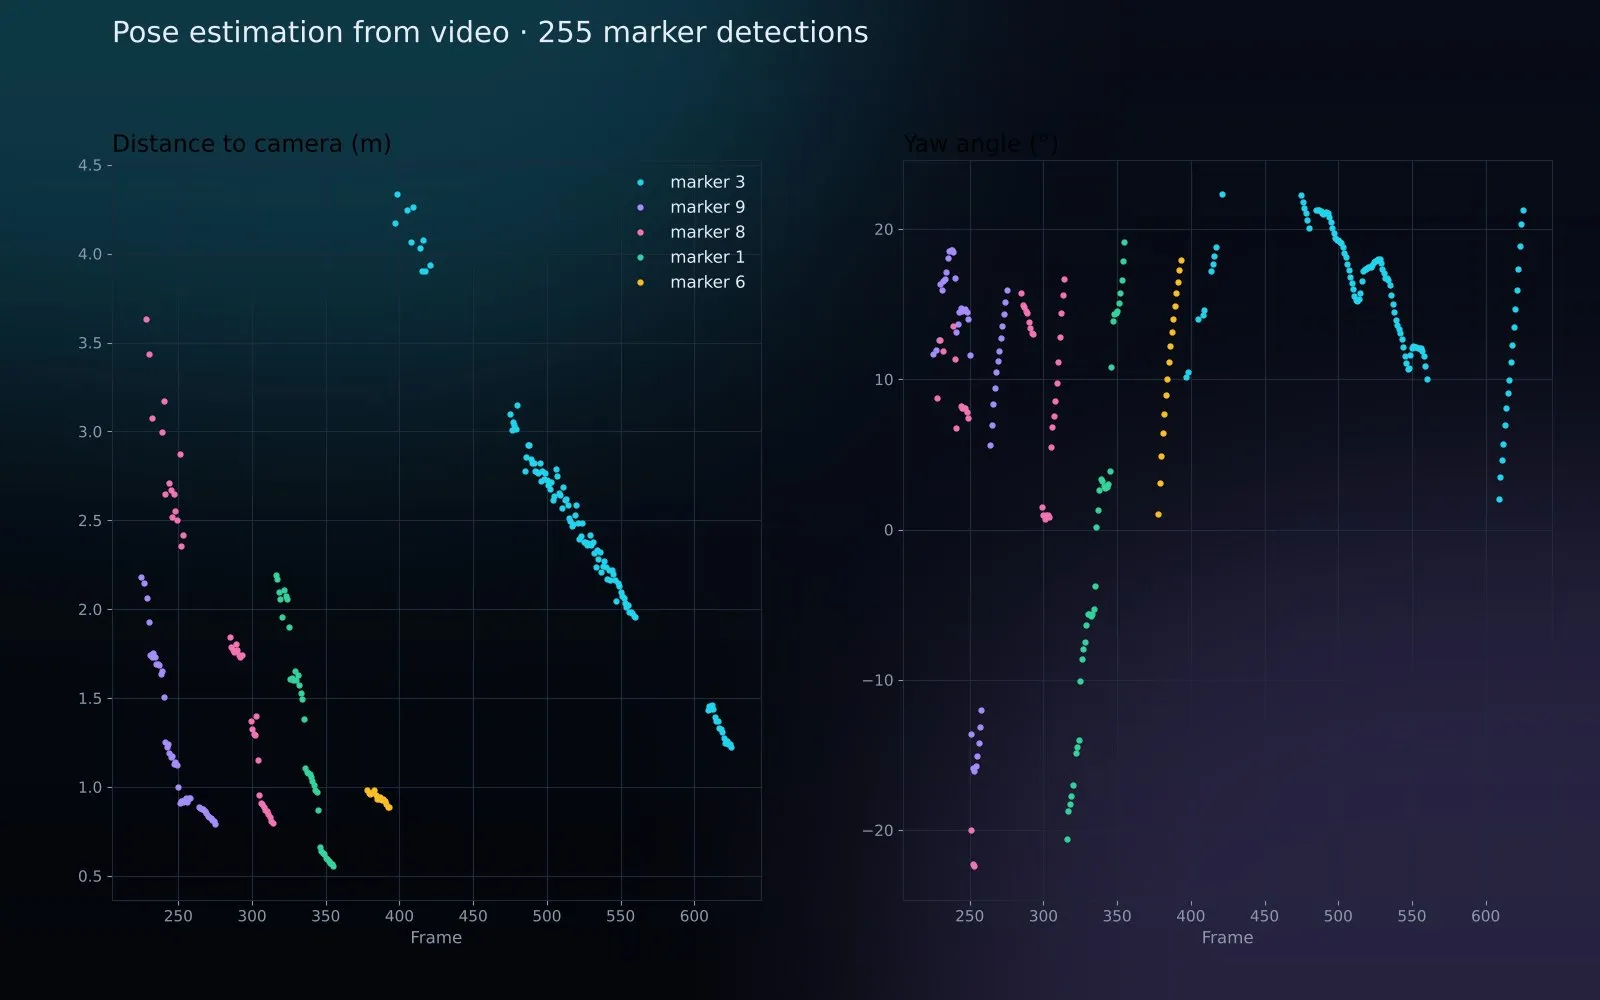
Detects ArUco markers in drone video, estimates each marker's distance, yaw, pitch and roll, annotates the video and exports per-frame data to CSV — groundwork for autonomous drone navigation.
What it does
For every frame of a video, the detector finds ArUco markers and annotates each with its ID, distance from the camera and yaw angle, outlining it in green.
It also writes a CSV with the marker’s 2D corners and 3D pose — distance, yaw, pitch and roll — so the results can drive a navigation algorithm, not just a demo.